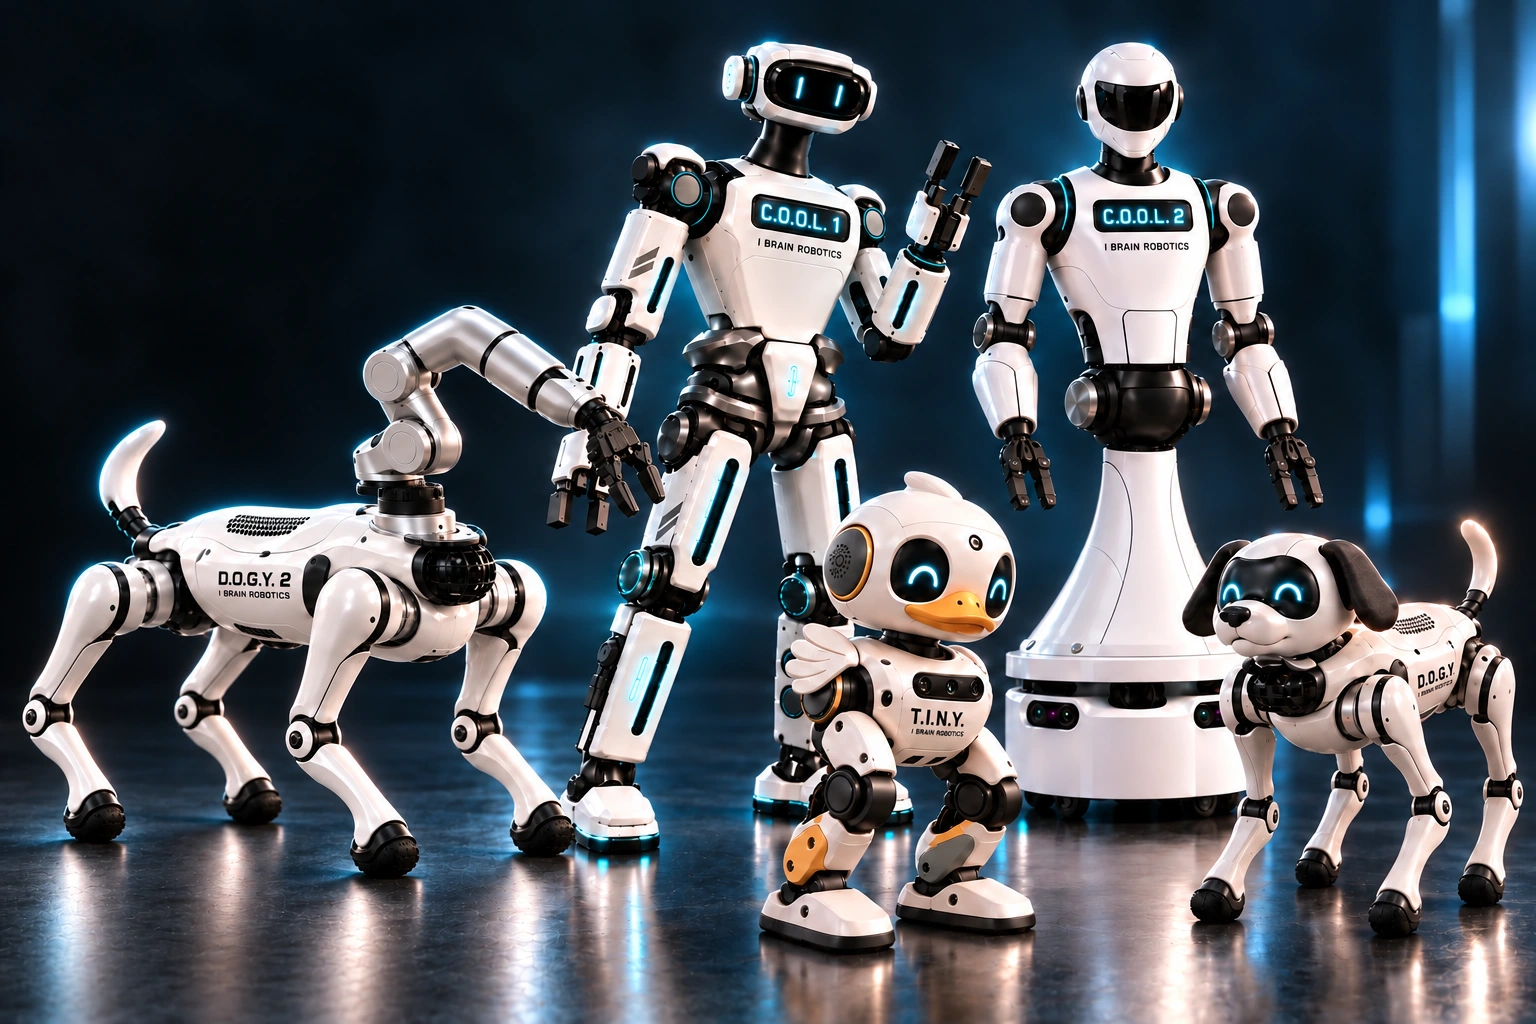
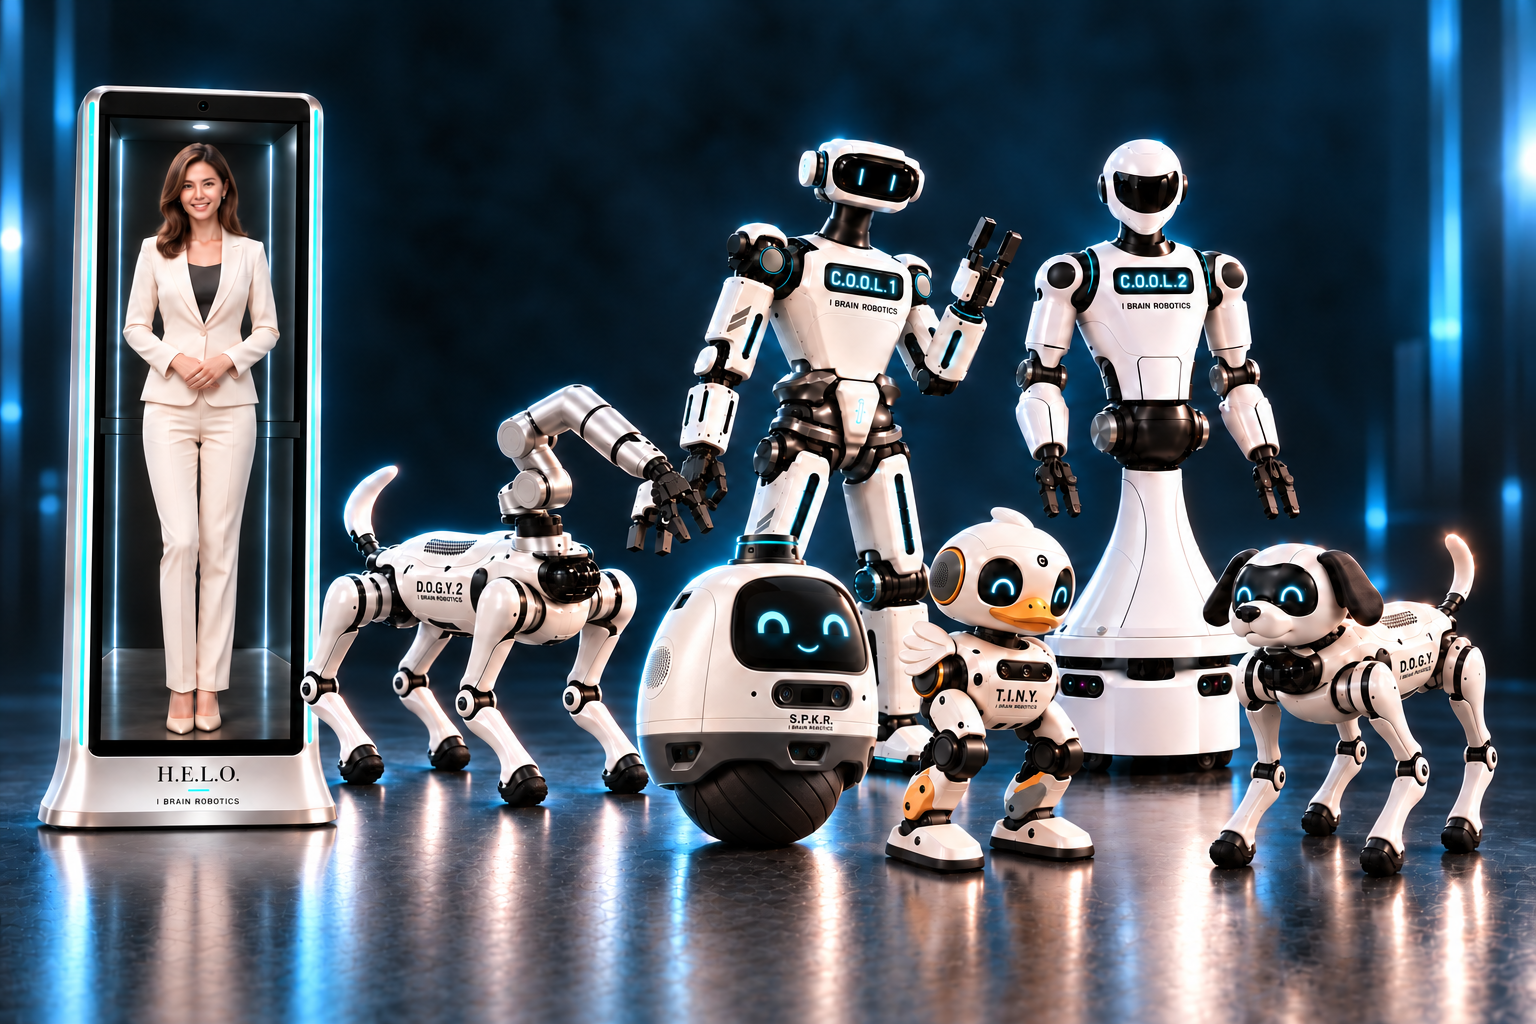
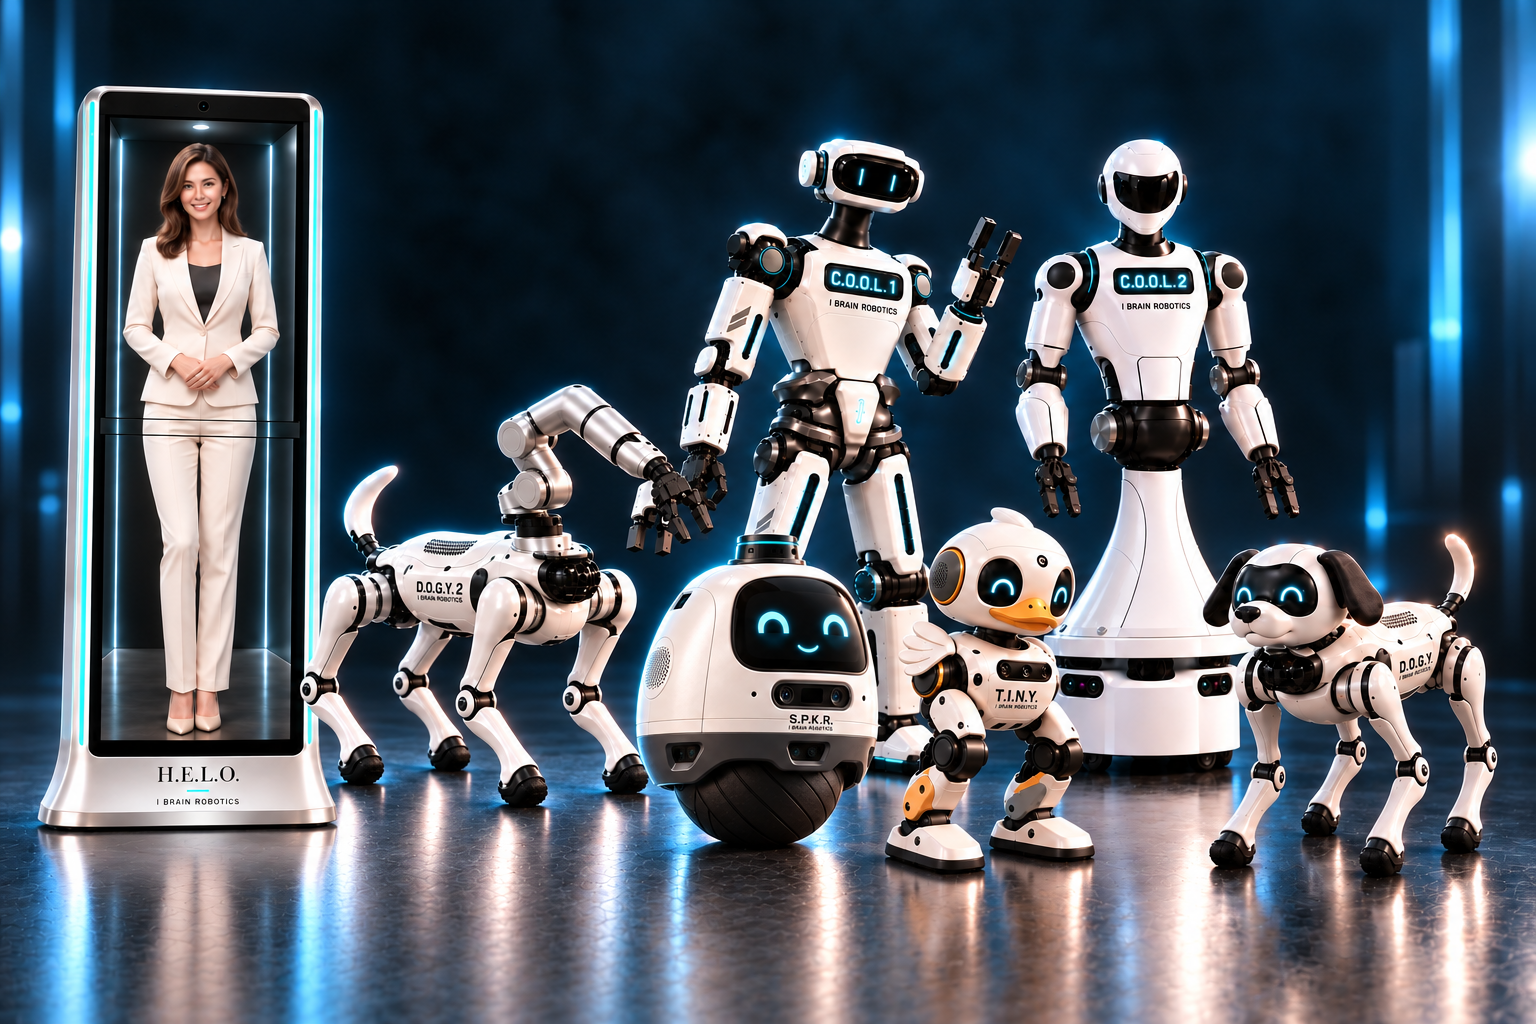
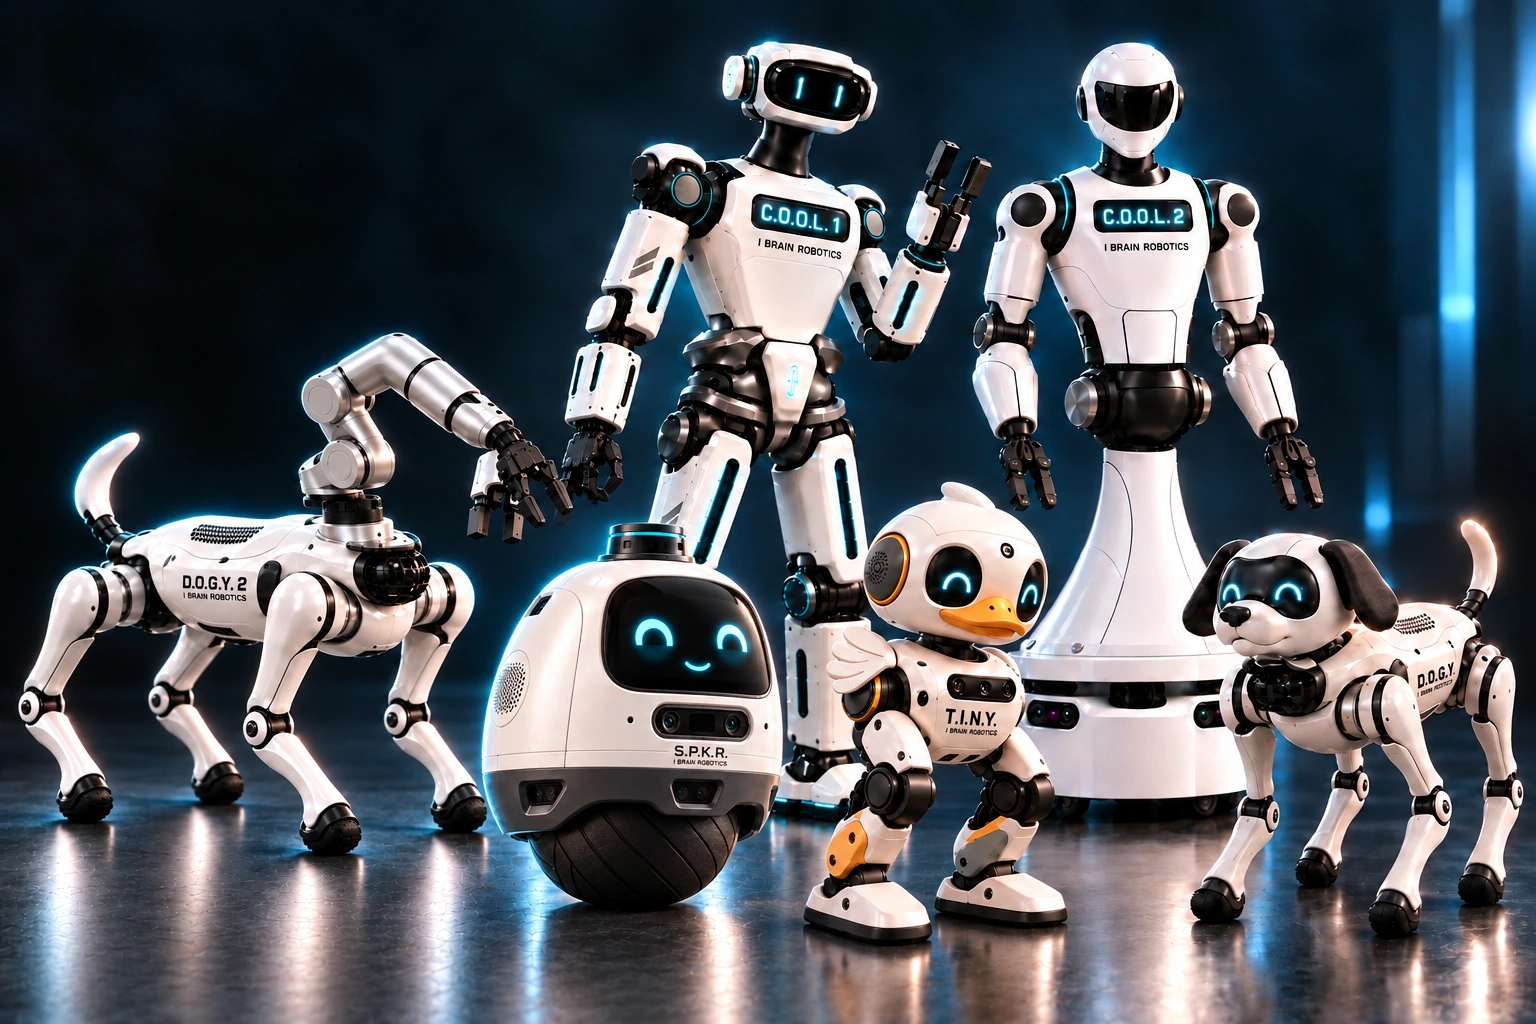
An arm, in place of a head
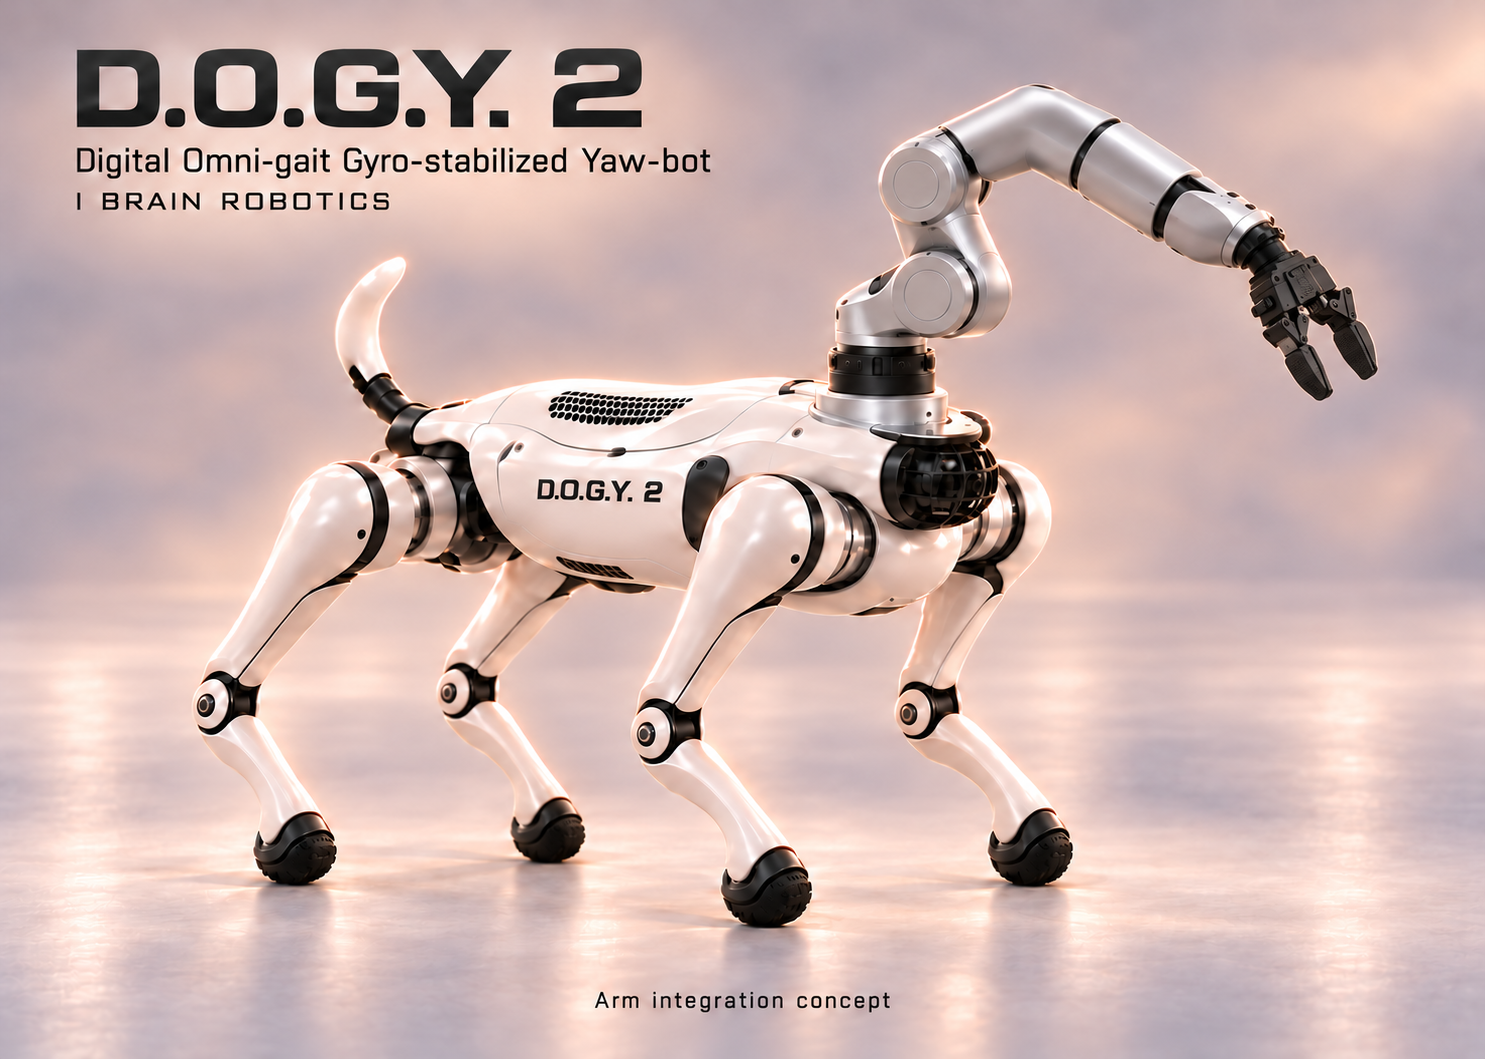
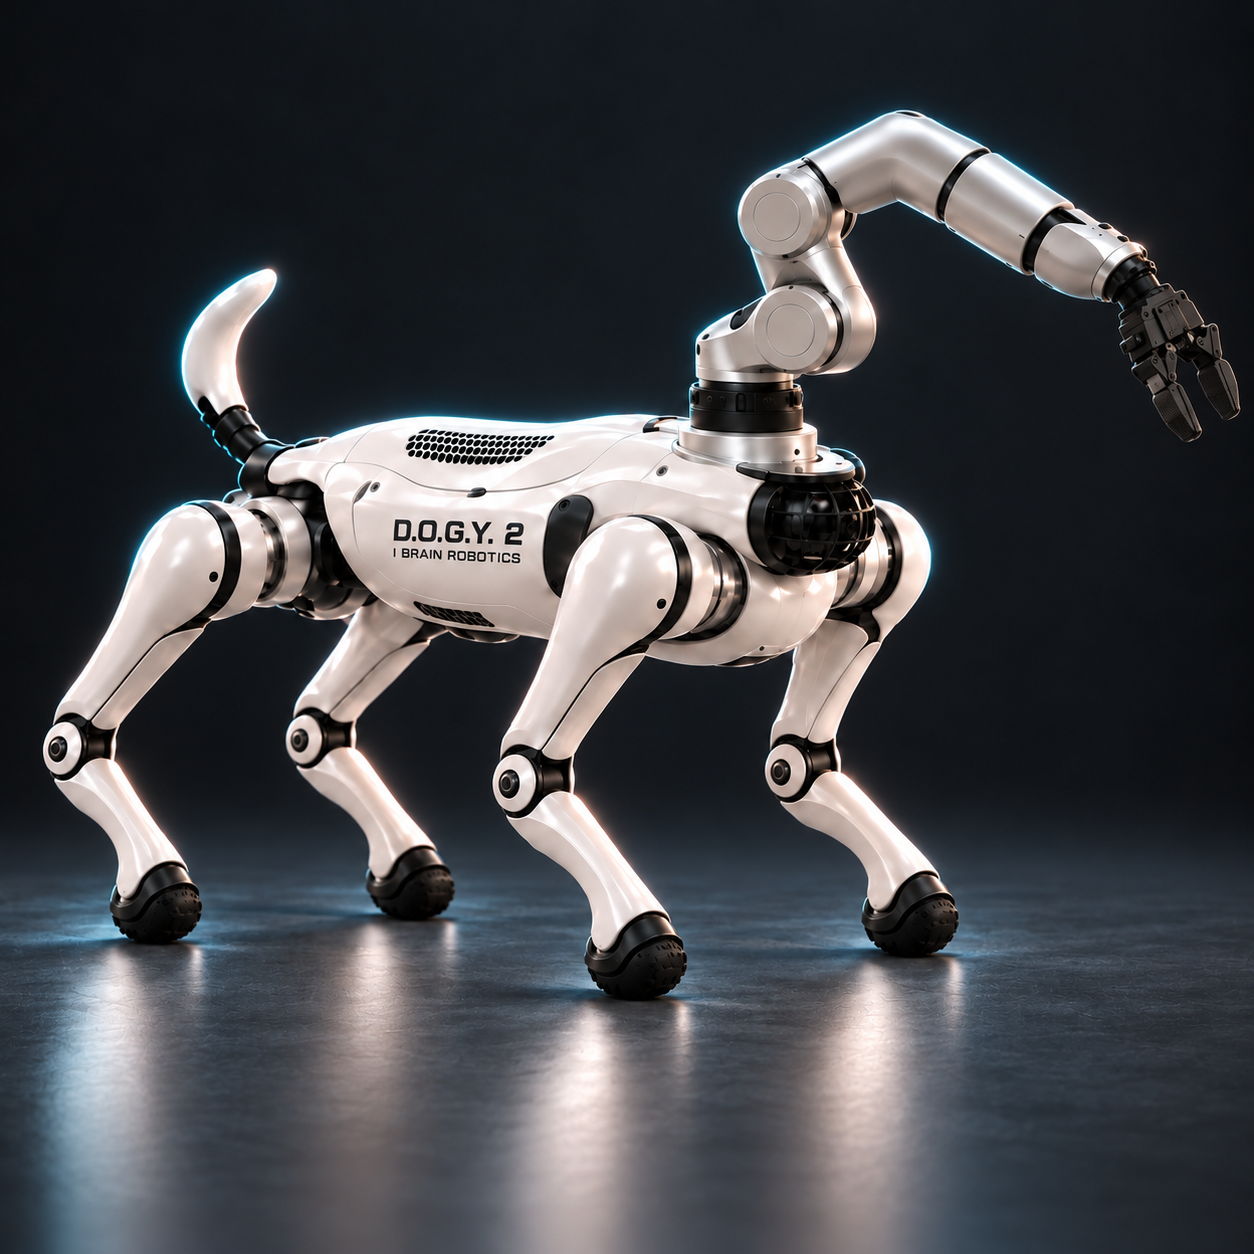
The front-mounted articulated arm defines D.O.G.Y. 2. Its forward-reaching configuration replaces the companion-style head, giving the robot a distinct manipulation-focused identity.
 Book a Demo
D.O.G.Y. 2
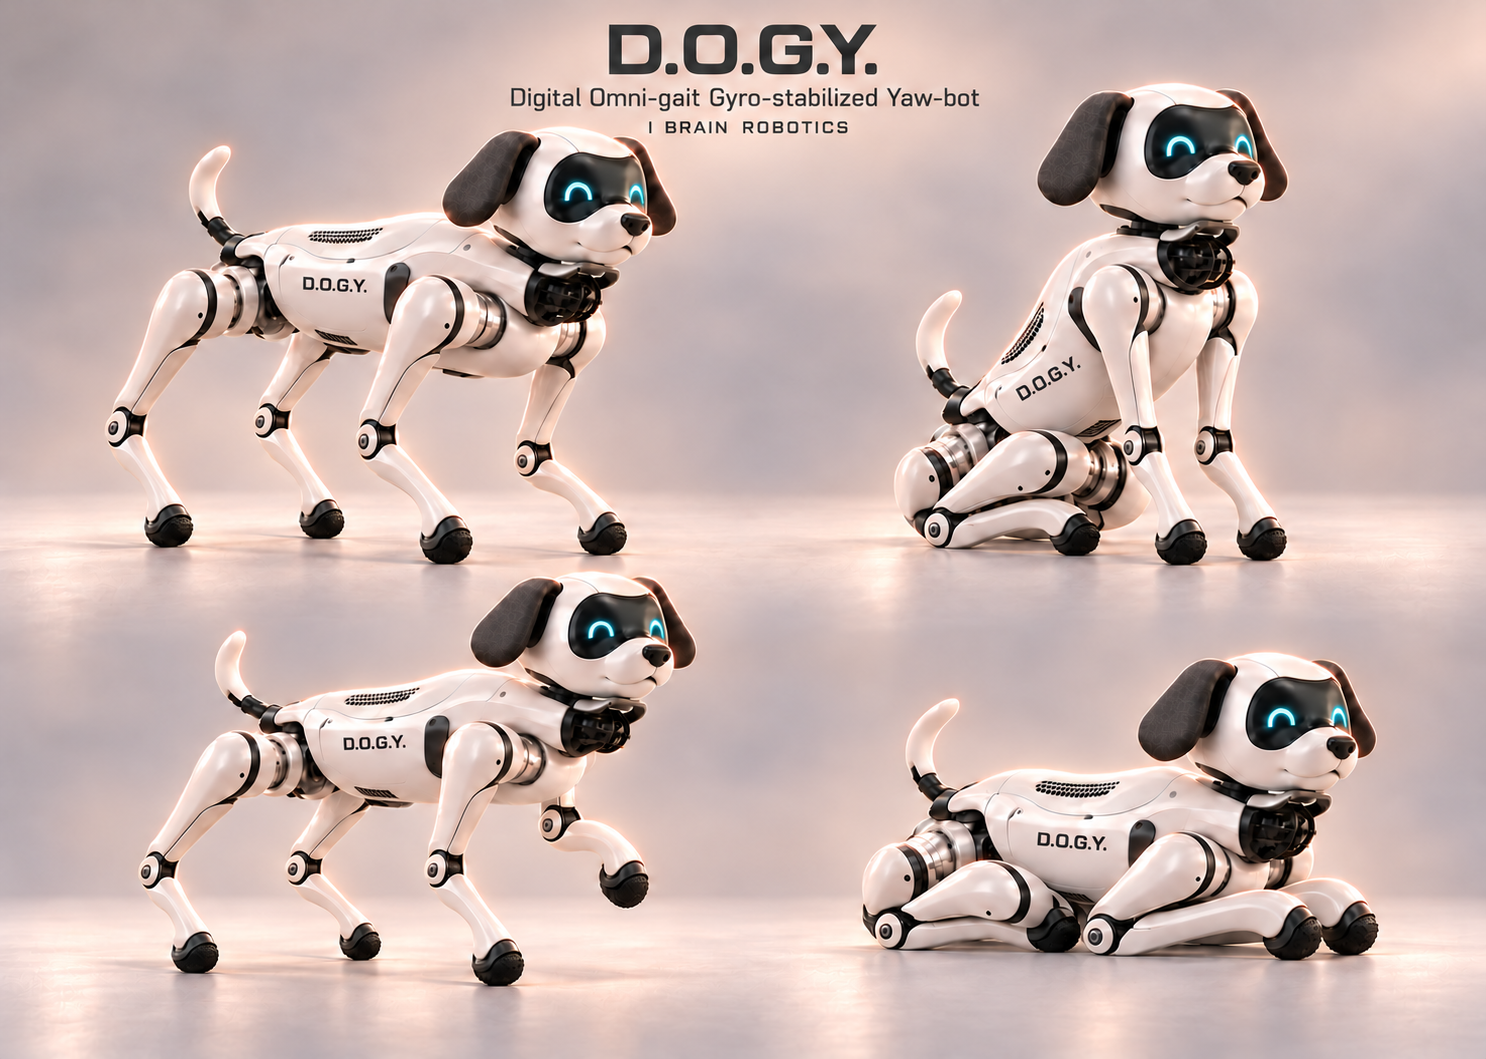
Digital Omni-gait Gyro-stabilized Yaw-bot
Quadruped mobility meets purposeful manipulation. D.O.G.Y. 2 pairs a sculpted four-legged body with a front-mounted robotic arm and a two-finger gripper, opening a new direction for supervised, hands-on robotics.
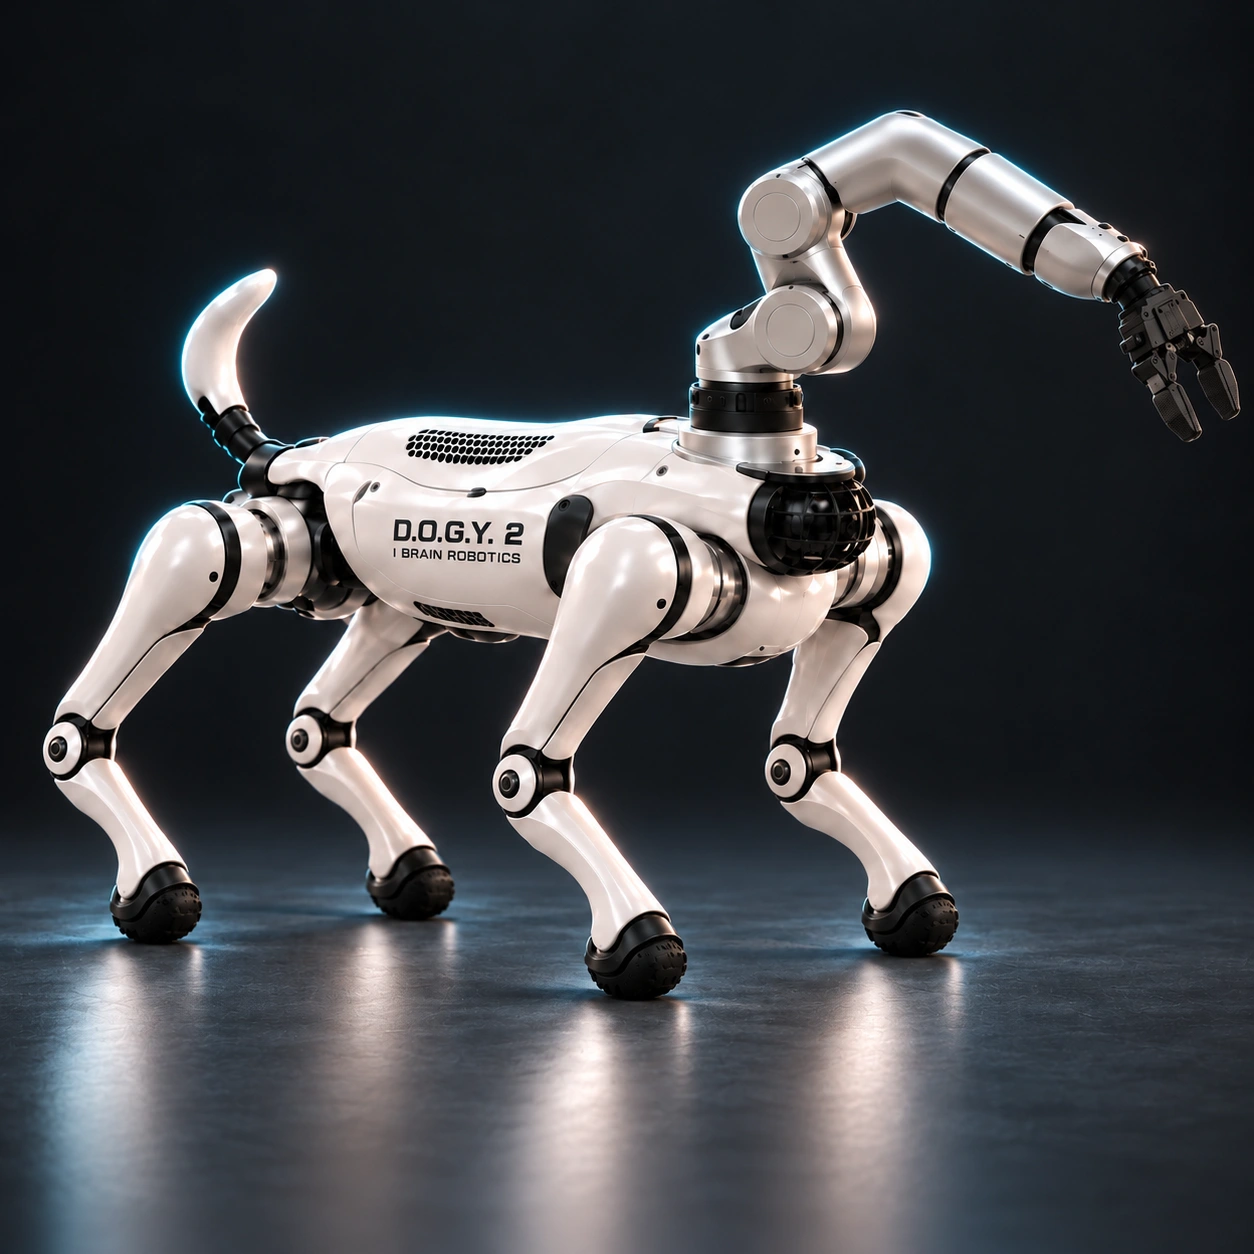 I BRAIN ROBOTICS / D.O.G.Y. 2
D.O.G.Y. 2 has a character of its own.
Discover what makes it unmistakable.
Hardware foundations and a clear development direction, brought together in one robot.
Four-legged movement on the As2 foundation
Seven-axis arm reference with parallel gripper
Front sensor clearance and task sensing integration
Joint planning of stance, reach and object handling
Explore the intended applications.
Help shape a pilot around your space and goals.
Explore coordinated legged movement and arm control, from approaching a workstation to supervised object interaction.
Discuss this applicationDevelop repeatable handling tasks with selected objects and prepared stations. Object weight, grip and reach must be defined for each pilot.
Discuss this applicationShow the relationship between perception, positioning and manipulation in guided robotics demonstrations and education programs.
Discuss this applicationApplication concepts describe intended uses. Supported tasks and operating environments will be defined through validation.
This is an arm-integration concept. As2 measurements refer to the unmodified quadruped; the R1-7a is the seven-axis arm reference. Neither component specification establishes the complete robot’s reach, lifting capacity, stability or runtime. The selected As2 edition, mounting structure, gripper and controls require engineering validation.
| Specification | Detail | Basis |
|---|---|---|
| Configuration | Quadruped with a front-mounted articulated arm | Integration concept |
| Base platform | Unitree As2; edition pending | Component reference |
| Arm reference | Unitree R1-7a Bionic 7 Axis Dexterous Robotic Arm | Manufacturer product reference |
| Arm articulation | 7 axes | Arm reference |
| End effector | Two-finger parallel gripper | Supplied design concept |
| Arm mounting | Front of body, replacing the companion head | Supplied design concept |
| Base standing dimensions | 720 × 378 × 457 mm | Unmodified As2; excludes arm and shell |
| Base mass with battery | Approximately 20 kg | Unmodified As2; excludes arm and shell |
| Base joint motors | 12 | Unmodified As2 |
| Base battery capacity | 8,000 mAh AIR; 15,000 mAh PRO / X / EDU | Edition-dependent component reference |
| Base connectivity | Wi-Fi 6 and Bluetooth 5.2 | Unmodified As2 |
| Development interfaces | Secondary development supported on X / EDU | As2 edition-dependent |
| Sensor arrangement | Front LiDAR shown below arm mount | Concept; sightlines require validation |
| Complete robot dimensions & mass | To be measured after integration | Not yet confirmed |
| Arm reach & working envelope | Dependent on mounting, joint limits and clearance | Not yet confirmed |
| Lifting capacity & gripper force | Task-specific validation required; base payload is not arm lift capacity | Not yet confirmed |
| Runtime & power system | Combined arm, base and electronics budget pending | Not yet confirmed |
| Motion & manipulation control | Coordinated locomotion and manipulation development | Planned |
| Availability & pricing | To be announced | Development program |
D.O.G.Y. focuses on a dog-inspired face and companion interaction. D.O.G.Y. 2 replaces that head with a front-mounted arm and two-finger gripper, making mobile manipulation its defining development direction.
The finished system’s lifting capacity has not been confirmed. It depends on the arm, gripper, mounting, reach and quadruped stance. The As2’s carrying-load figures must not be interpreted as arm lifting capacity.
Coordinated movement and manipulation are intended development goals. Supported objects, grasp positions and motion limits will be published after complete-system testing.
Follow its development or tell us about the experience you want to create.
No payment or reservation required.